AG./arsalanghogari.com
seeking new-grad SWE roles · graduating May 2027 · Los Angeles · press ⌘K or `
Computer Science + Business · USC

Building AI products, autonomous robots, and software that scales.

Perception  •  SLAM  •  RAG  •  Systems

illustrative simulation · barracuda auv
Detect. YOLO + RT-DETR on-vehicle.
02

About

human 0.99 Arsalan Ghogari

CS + Business at USC, specializing in AI applications. I build perception and autonomy for robots, retrieval systems that ship to thousands of users, and the tooling around them.

Currently: software lead on an autonomous sub, AI engineer on an industry capstone, and owner of a platform used by 20,000+ students. Looking for new-grad SWE roles, May 2027.

03

What I’ve Built

Projects

RoboSub Perception On-Vehicle Object Detection
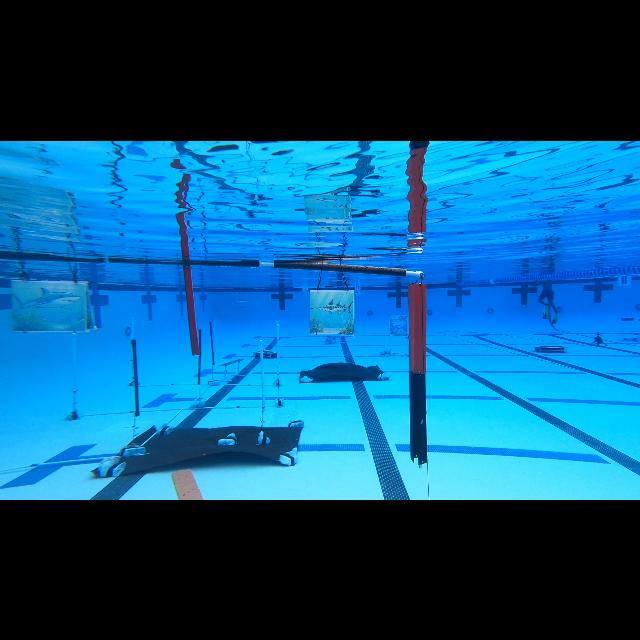
Underwater pool frame from the AUV's camera loading model… yolo · onnx int8 · onnxruntime-web
the AUV's own YOLO weights · not a video — every box is computed on this device
Custom dataset built from ROS bags; YOLO + RT-DETR trained and compiled ONNX → TensorRT (FP16/INT8) for real-time inference on the Jetson. Detection mAP 0.40 → 0.90. The model above is the real one, running in your browser. Python · PyTorch · YOLO · RT-DETR · ONNX · TensorRT
RoboSub Localization GTSAM Factor-Graph SLAM
gategatered pipered pipered pipebin GTSAM · LM optimizer poses 60 landmarks 6 factors 54 iter 0 graph error 33.741 worst landmark – spec: all landmarks < 0.30 m real optimizer · synthetic obs
Stereo (ZED) landmarks, IMU, DVL, and depth fused in a GTSAM factor graph that drives costmap navigation. Validated on rosbag replay against surveyed prop placement: every landmark under 0.3 m absolute error. The graph above is a real optimizer run through the estimator's own code. C++ · Python · ROS 2 · GTSAM · Eigen
Ask USG ● Live Production RAG Chatbot query BM25 pgvector RRF fuse +siblings answer MRR 0.91 → 0.98 TTFT 6.2 s → 0.5 s answer quality 83% → 95% · 1,100 beta questions illustrative Production RAG for 20,000+ students: hybrid BM25 + pgvector retrieval, sibling-chunk expansion, SSE streaming, LangGraph tool routing. Answer quality 83% → 95% on 1,100 real beta questions; time-to-first-token 6.2 s → 0.5 s. Python · Node/Express · OpenAI · pgvector · LangGraph · Docker PTDrone ● Live Drone Ground Control & Manufacturing Cell (Capstone)
microfactory v6 · concept model hover to peel · drag to rotate loading model…
Capstone with an outside stakeholder: drone ground-control station, a parts chatbot that triggers on-demand manufacturing, and a simulated manufacturing cell. Next.js static export on Render with preview-branch gating. Next.js · React · TypeScript · Render
Parley AI Voice Negotiation Agent Vendor A—Vendor B—Vendor C—leverage: competing bids · honesty tripwires in code41 CI-gated tests Solo hackathon build: a voice agent that finds vendors via Google Places, phones them, and negotiates with competing bids as leverage. Real $2,400 → $2,250 result, honesty tripwires in code, 41 CI-gated tests. Next.js · TypeScript · ElevenLabs · GPT-4o · Supabase Shroom AI Seasoning Carousel ESP32-driven seasoning carousel with a React UI; GPT pairs what's on hand with a meal and spins to the jar. React · Tailwind · GPT · ESP32 Postcards from Bristol ● Live Interactive 3D Photo Carousel Drag-to-spin 3D photo carousel in vanilla JS, pointer and keyboard driven, from my exchange semester. HTML · CSS · JavaScript AnchorNotes Collaborative Note-Taking App Android note-map app, top 2 of 37 teams. 70% faster than peers via Profiler-guided optimization, thread offloading, and indexing. Java · XML · Android Studio
PythonC++CUDAJavaJavaScriptTypeScriptSwiftCMATLABOpenAI APILangGraphLangfuseRAGROS 2PyTorchTensorRTONNXGTSAMNVIDIA Isaac SimReactNext.jsNode/ExpressSwiftUIPostgreSQLpgvectorAWSStripeWordPressRenderDockerK3sGitHub ActionsGitLinux/Bash
04

Experience

Software Lead PTDrone (CSCI 401 Capstone)

Aug 2026 — Present

Lead a five-person team building for an outside stakeholder: scope and ship the public site, the drone ground-control station, and the on-demand manufacturing flow. Modeled the Microfactory in Blender (the one you can peel open above) and run the Next.js + Render pipeline with preview-branch gating.

Next.jsTypeScriptBlenderRenderLeadership
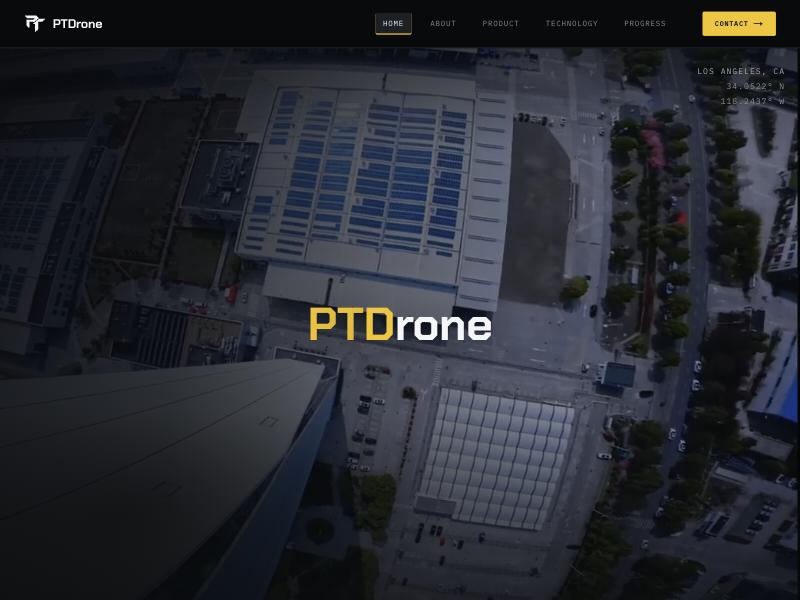
ptdrone.techlive · scroll inside
PTDrone website (ptdrone.tech) homepage

AI Engineer USC Industry Collaboration Program

Sep 2026 — Present

Sole AI engineer on a student team automating a core internal workflow for a Canadian construction company, requirements to delivery (details under NDA).

AI EngineeringLLMsProduct
AI MODEL OUTPUT WIRED INTO THE BUILD

Software Lead USC RoboSub

Jan 2025 — Present

Lead a 5–10 engineer team on the AUV's full autonomy stack (ROS 2, Jetson). Migrated 10,000+ lines ROS 1 → ROS 2, took detection mAP 0.40 → 0.90 with YOLO + RT-DETR on TensorRT, shipped GTSAM SLAM holding every landmark under 0.3 m, and retuned the CUDA MPPI controller after root-causing a 12 N thrust clamp from 75 GB of wet-test data.

PythonC++CUDAROS 2PyTorchTensorRTGTSAM
uscfrl.comlive · scroll inside
USC AUV / RoboSub team site (uscfrl.com) homepage

Director of Digital Strategy USC Undergraduate Student Government

May 2025 — Present

Own the platform serving 20,000+ students. Built automated Funding, Senate Bill, and Legislative trackers that made $352K of spending searchable and cut manual reporting 95%; ship front-end features on the WordPress site.

JavaScriptWordPressLeadership
usg.usc.edulive · scroll inside
USG website (usg.usc.edu) homepage
05

Education

University of Southern California

B.S. Computer Science + Business Administration · Expected May 2027

Viterbi School of Engineering & Marshall School of Business · Minor in AI Applications

Study Abroad — University of Bristol, UK (Spring 2026)

3.9 GPAPresidential ScholarViterbi ScholarW.V.T. Rusch Honors